WORK PACKAGES
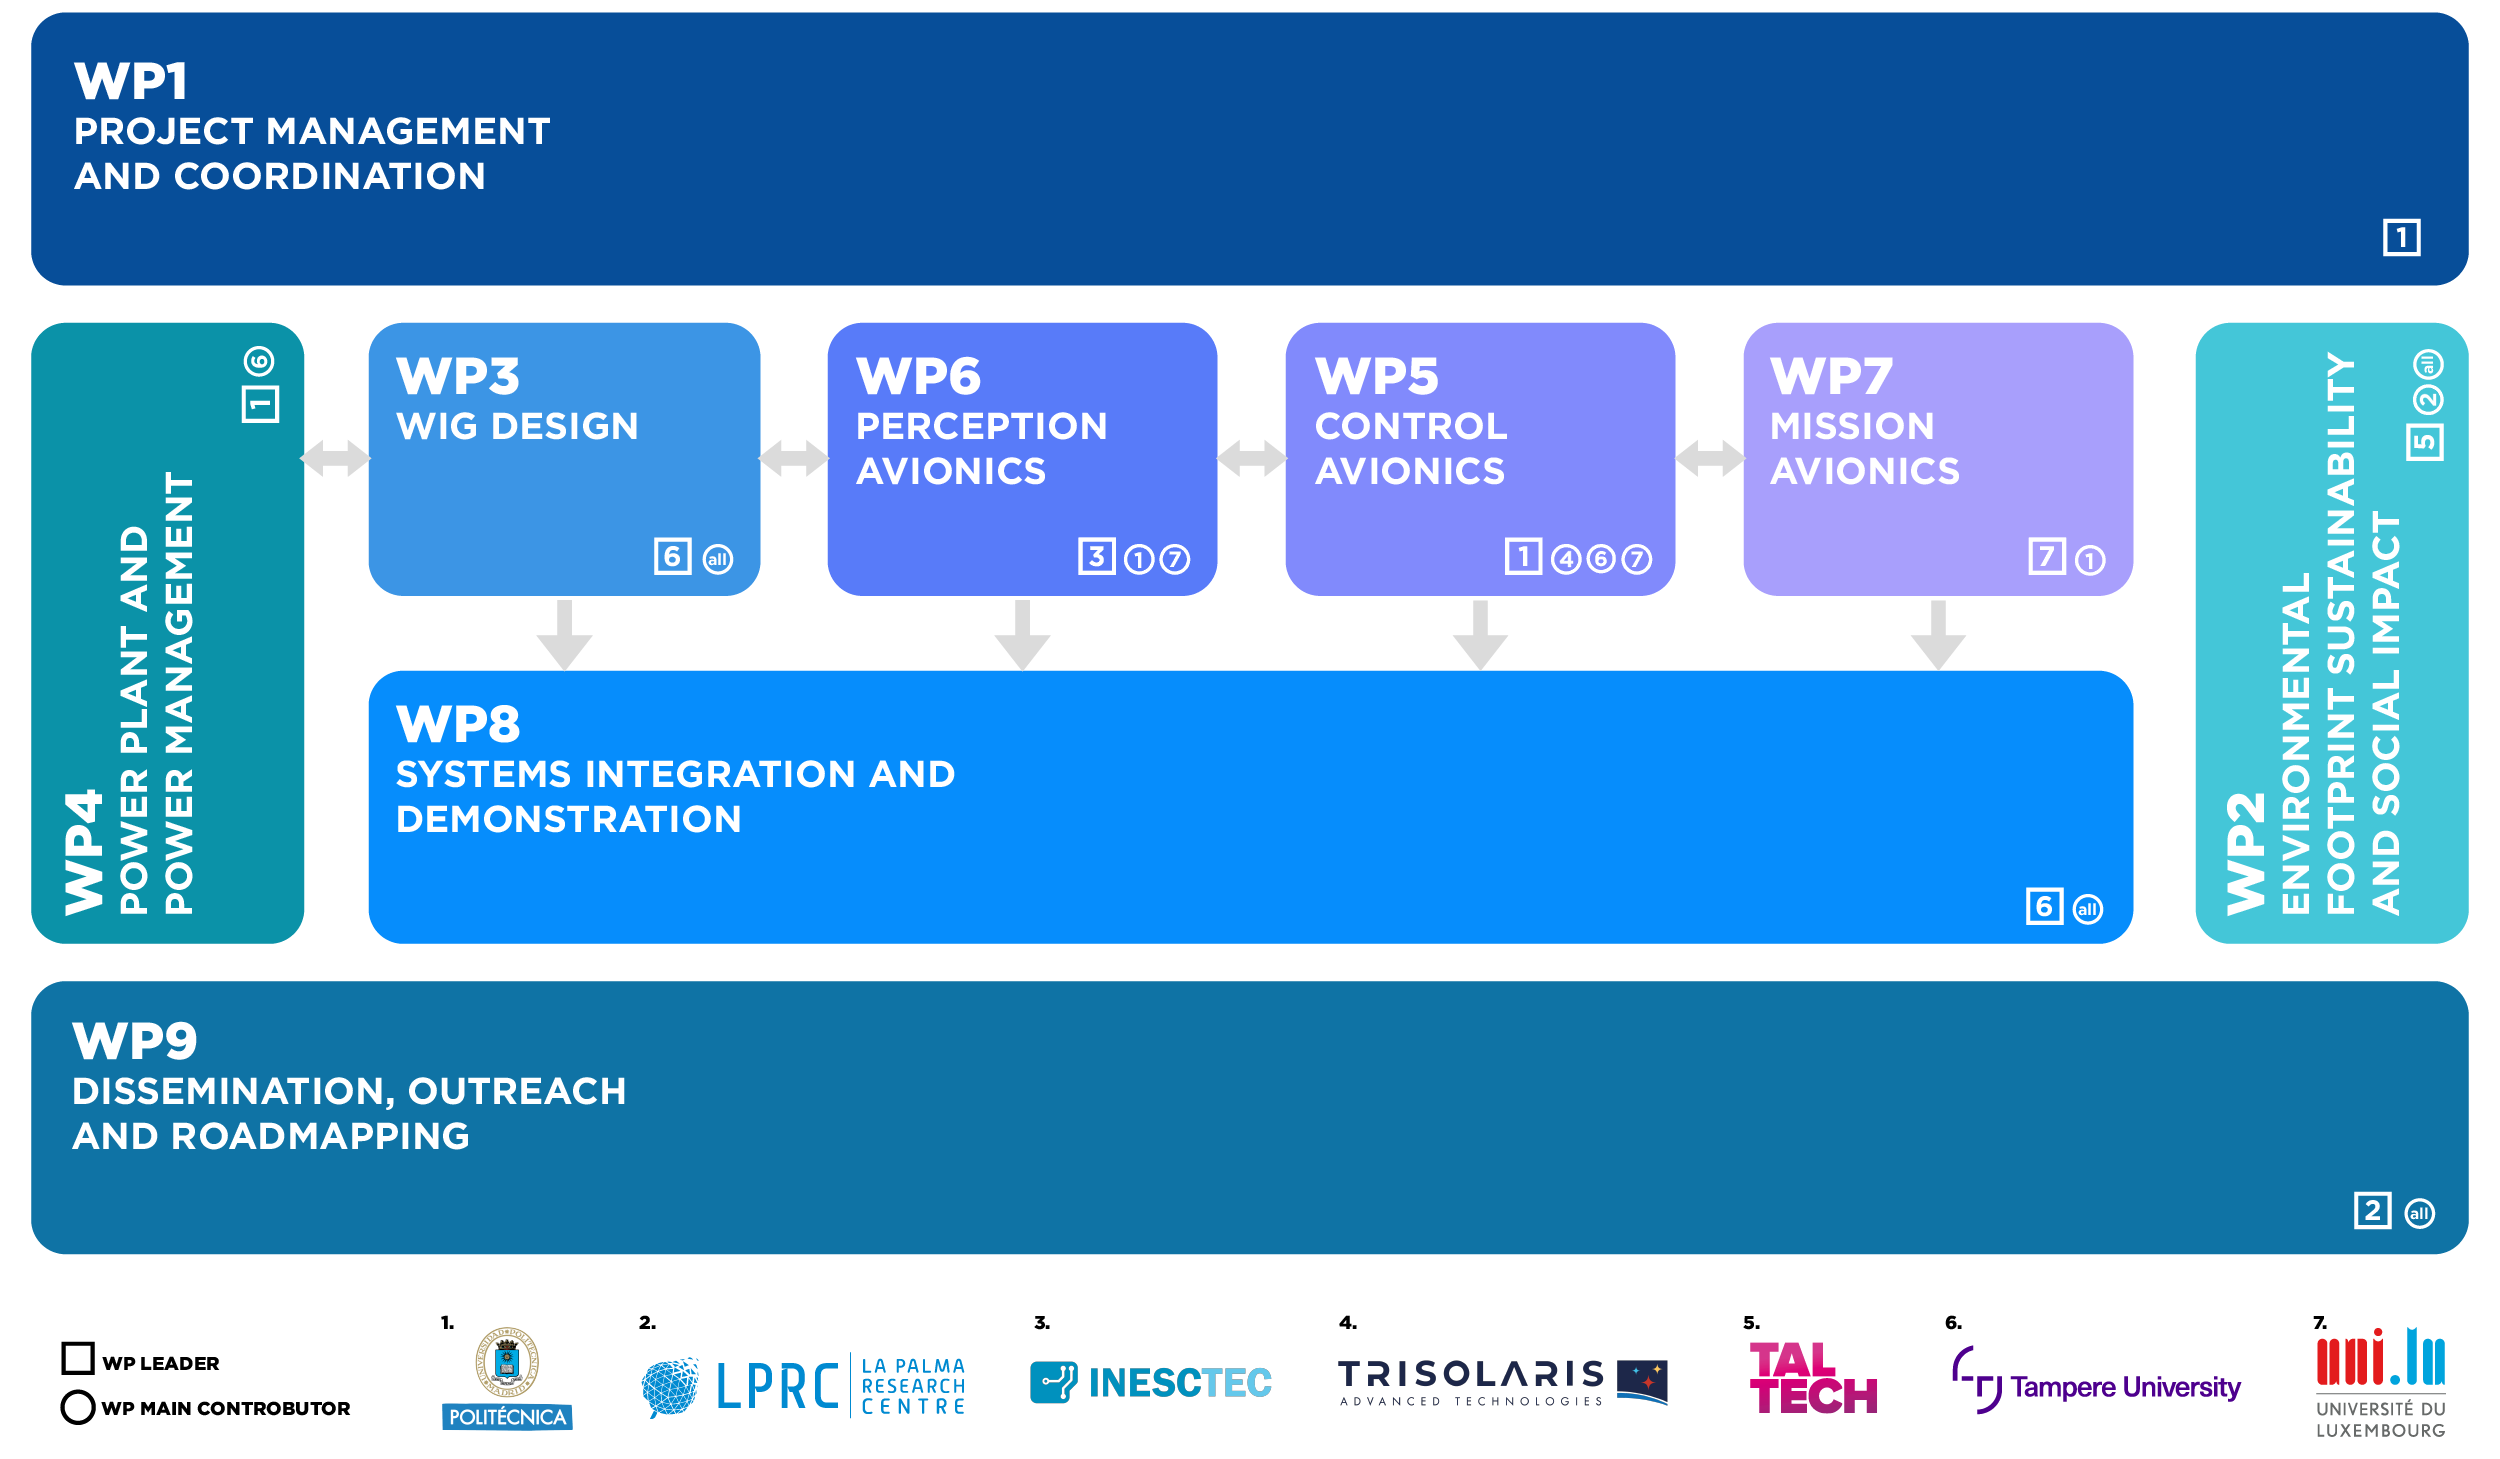
WP 1 will ensure efficient project management in line with the AIRSHIP Grant Agreement and Consortium Agreement.
WP 2 will start defining application scenarios and their requirements, which in turn will set technical requirements. Studies regarding environmental footprint and sustainability, as well ethics and social impact will be carried out. Detailed market, services and business models will be performed.
D2.1 Integrated sustainability assessment framework (31.12.2023)
D2.2 Report on economics and business cases (31.12.2024)
D2.3 Social impact study (31.12.2025)
D2.4 Environmental footprint and sustainability: TBD (31.12.2026)
WP 3 will study and simulate different known configurations of WIG crafts, as the basis to propose the most suitable design for the project goals. CFD simulation (A0-D model) and wind tunnel tests (A10-W model) will be performed. This WP will output blueprints for both the scaled A0-PSmodel and the AIRSHIP-1 model
Study, optimization and development of innovative, zero-emission power systems based on DC Microgrids, integrating green energy sources and energy storage to implement fully electrical propulsion system for WIG (reaching TRL 4). Design, implementation and validation of the Digital Twin model of the WIG propulsion DC Microgrid.
To develop dynamical models, simulations and fundamental controllers for the aircraft.
D5.1 Control system design for the dynamic model (31.12.2023)
D5.2 Results of control system on physical model (31.12.2025)
D5.3 Report on SW-in-the-loop and HW-in-the-loop (30.06.2026)
WP 6 will address the research and development of sensing and perception methods, algorithms and approaches to enable AIRSHIP autonomous drones with novel perception and awareness capabilities. These capabilities must be developed to enable the systems with low latency and long range detection and tracking of possible obstacles, that allows the implementation of collision avoidance rules. In addition, multi sensory approaches and fusion methods will be explored and validated for accurate and real time sea wave perception and modelling.
D6.2 Real-time multi-modal sensor fusion for awareness (31.12.2025)
D6.3 Real-time perception and modelling of sea/ground surface (31.12.2026)
D6.4 Situational awareness developments (31.12.2026)
To study and develop innovative guidance, navigation and control techniques tailored for the specific features of the WIGs, as well as self-awareness and situational awareness capabilities for the vehicle.
D7.1 GNC system and simulations (30.06.2025)
D7.2 Meta-controller and simulations (31.12.2026)
WP 8 will integrate different HW and SW components in order to provide final tests and demonstrations at a technological readiness level of “4.5” for the AIRSHIP-1 autonomous WIG. Candidate tests areas ar the Inner Seas of the Baltic Area or the Macaronesia archipelago. Specific objectives are: 1) Implement an architecture for the AIRSHIP platform to operate autonomously; 2) Adapt and integrate the technological components (HS & SW) for operations; 3) Organise local logistic, supervision system, launch & recovery system for tests, 4) Conduct and evaluate a series of trials. Recorded visual materials (pictures, movies, etc…) collected will be used for producing demonstration data sets and movies showing results and potential applications of this technology.
WP 9 will maximise the impact of AIRSHIP by deploying an efficient communication, dissemination and
exploitation strategy. At the same time, it will engage with stakeholders (internal and external) to draw innovation
pathways for future implementation of the AIRSHIP technology line.
D9.2 Stakeholder analysis (30.06.2024)
D9.4 Dissemination, Exploitation, and Communication report (31.12.2024)